Asier Zubizarreta :: Projects

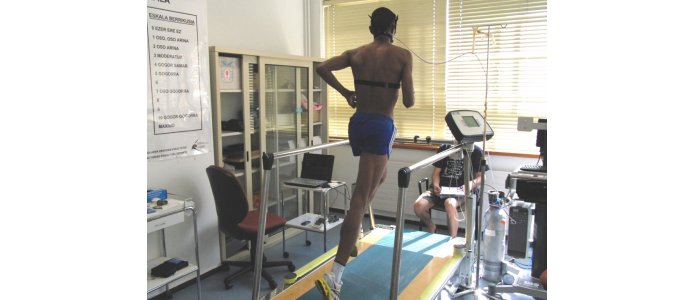
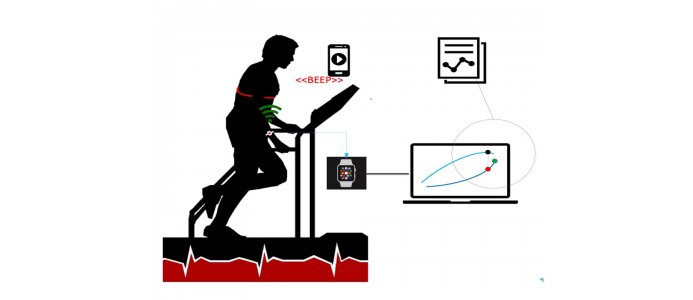
Advanced support system for endurance training based on a Virtual Lactate Sensor implemented by Artificial Intelligence techniques (IG-2015/0000062)

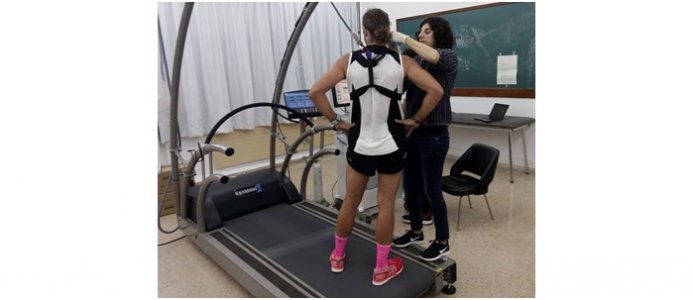
During the last years, it is clear the growing importance of endurance sports, especially middle- and long-distance races, included or not within the also very popular endurance triathlon. Currently, these athletes support the workouts on a smart watch or heart rate monitor as well as software applications for analysis and statistics. These software applications make possible to analyze a posteriori data itineraries, to make comparisons, to obtain statistical values, ... facilitating the realization of comprehensive and...

Read more
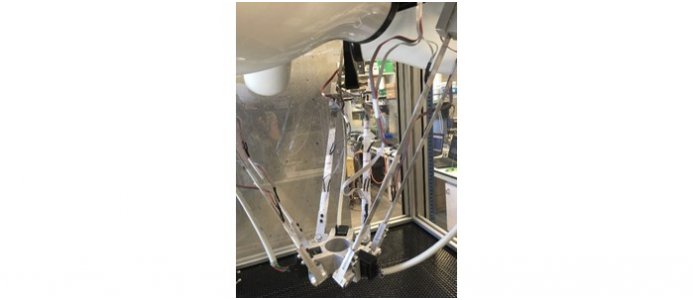
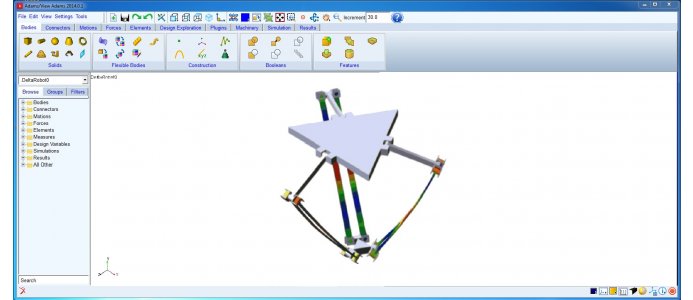
Advanced control of parallel robots for high performance applications in the automotive sector. Control avanzado de robots paralelos para aplicaciones de alto rendimiento en el sector de la automoción (S-PE11UN110)

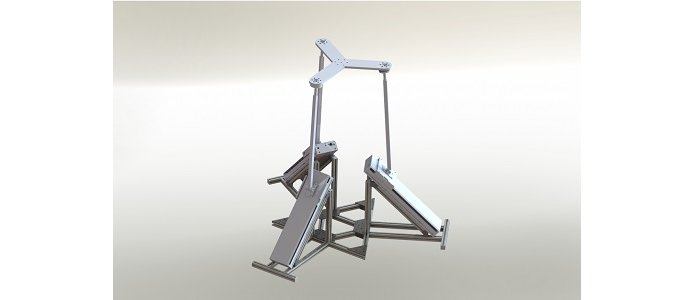
The main objective of this project is to analyse the capacity of current parallel kinematic structures as a test bench for automotives, allowing for a reduction in the cost of developing these elements and the necessary testing hours on track. For this, we will approach from several areas. First, we will look at the synthesis and design of parallel robots, in order to determine the most adequate structure to meet the needs of the application, as well as the sizing. Second, kinematic and dynamic modelling will allow...

Read more

Real-time position-strengh control based on elastic models for high performance applications of parallel robots. Control de posición-fuerza en tiempo real basados en modelos elásticos para aplicaciones de alto rendimiento de los robots paralelos (DPI2012-32882)

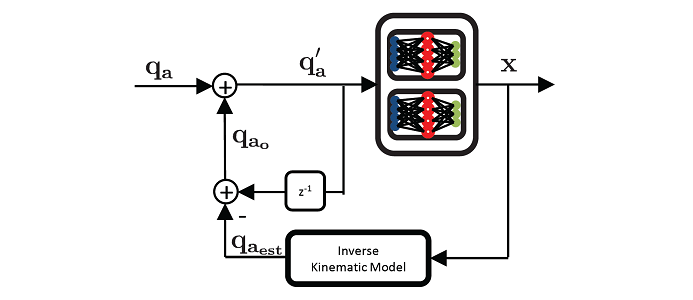
Parallel robots have proven to be the best alternative for dynamic high performance applications in which we need to manipulate powerful changes, apply controlled forces efficiently or move objects at high speed. For this, we require a correct mechanical design as well as an adequate controller that can be executed on real-time. Thus, the aim of the project is to develop specific control techniques for parallel robots in high dynamic performance applications.

Read more
1 2 3 4 5 6